The Concept
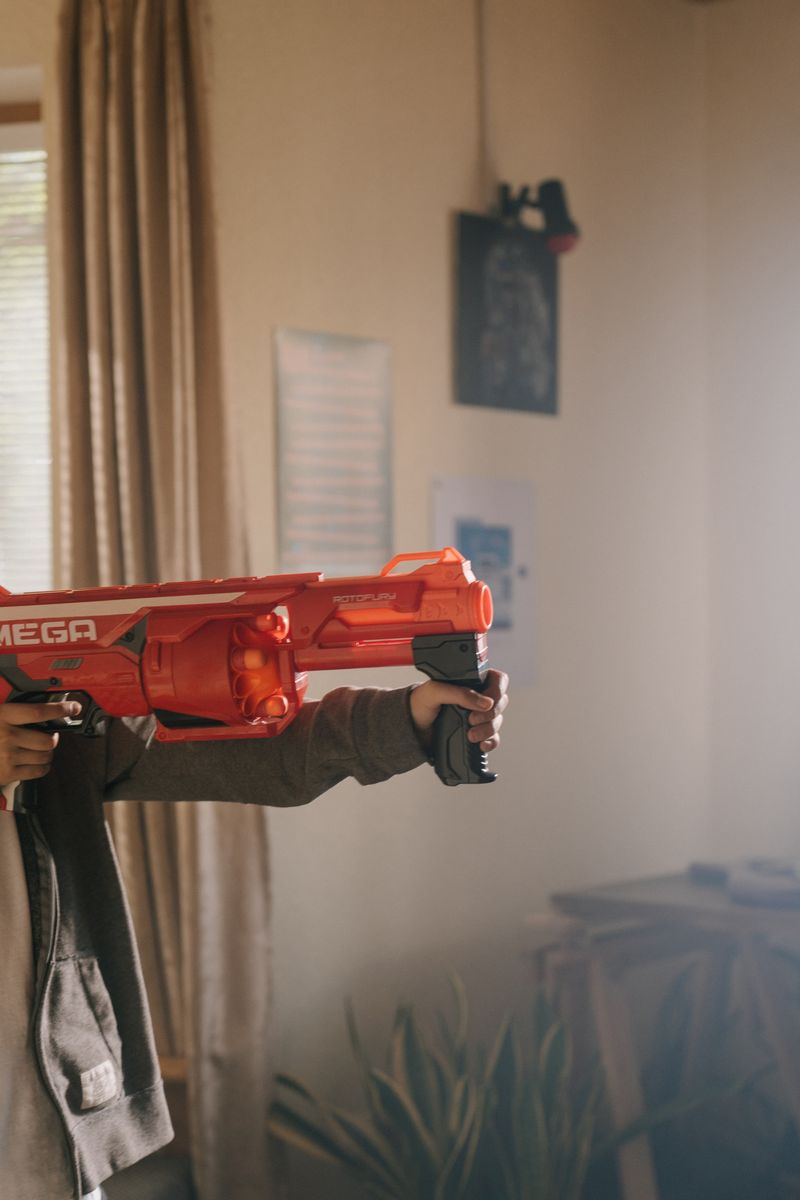
Motorized Nerf blasters are already halfway to being a robot. They've got flywheel motors that spin up on a trigger pull and a pusher mechanism that feeds darts. Your job: remove the human from the loop.
Mount the blaster on a pan/tilt servo platform, add a webcam running face or color detection, and let the computer decide when to fire. The result is an autonomous sentry turret that tracks targets and dispenses foam justice.
What You Bring
The kit includes the pan/tilt turret hardware, relay board, and targeting software. You supply:
- Motorized Nerf blaster — Stryfe or Rapidstrike recommended (flywheel-driven, easy to trigger electronically)
- Raspberry Pi 4 / 5 — runs OpenCV face tracking and servo control
- microSD card — 16GB recommended (OS + OpenCV libraries)
- USB webcam — any 720p+ USB camera (or use Pi Camera with included CSI adapter)
- 5V / 3A power supply — wall adapter or battery pack for the Pi
- Nerf darts — bring plenty for calibration and competition
What's Included in the BYOB Kit
- Pan/tilt servo rig (2x MG996R servos + aluminum bracket)
- Electronic trigger relay module
- CSI camera adapter cable (for Pi Camera option)
- Emergency kill switch with wiring
- Blaster mounting clamp (adjustable, fits most Nerf models)
- Pre-crimped wiring harness with labeled connectors
- Complete source code, wiring diagrams, and setup documentation
What You Bring
The Full Send Kit includes all electronics and hardware. You supply:
- Motorized Nerf blaster — Stryfe or Rapidstrike recommended (flywheel-driven, easy to trigger electronically)
- Nerf darts — bring plenty for calibration and competition
What's Included in the Full Send Kit
- Raspberry Pi 4B — pre-loaded with OpenCV targeting software
- 16GB microSD card — pre-imaged with Raspberry Pi OS and OpenCV
- USB webcam (720p+)
- USB-C power supply (5V/3A)
- Pan/tilt servo rig (2x MG996R servos + aluminum bracket)
- Electronic trigger relay module
- CSI camera adapter cable (for Pi Camera option)
- Emergency kill switch with wiring
- Blaster mounting clamp (adjustable, fits most Nerf models)
- Pre-crimped wiring harness with labeled connectors
- Complete source code, wiring diagrams, and setup documentation
What You Bring
A face-tracking autonomous Nerf turret. Plug in, load darts, and watch it acquire targets.
- Nerf darts — bring plenty for calibration and competition (starter pack included)
What's Included — Ready to Use
- Nerf Stryfe mounted on pan/tilt turret with Pi, camera, and tracking software
- Raspberry Pi 4B — pre-loaded with OpenCV targeting software
- 16GB microSD card — pre-imaged with Raspberry Pi OS and OpenCV
- USB webcam (720p+)
- USB-C power supply (5V/3A)
- Pan/tilt servo rig (2x MG996R servos + aluminum bracket)
- Electronic trigger relay module
- CSI camera adapter cable (for Pi Camera option)
- Emergency kill switch with wiring
- Blaster mounting clamp (adjustable, fits most Nerf models)
- Pre-crimped wiring harness with labeled connectors
- Complete source code, wiring diagrams, and setup documentation
Every Zero Shot unit is hand-assembled, firmware-loaded, sensor-calibrated, and QA tested before shipping. Premium boxed packaging included.
Project Files — Included with BYOB Kit
Complete source code, wiring diagrams, and documentation. Enter your kit code to unlock.
Don't have a code? Get the kit — code included in every box.
Step-by-Step
Choose & Disassemble the Blaster
The Nerf Rapidstrike is ideal — it's fully automatic with separate flywheel and pusher motors, both easily controlled electronically. Open the shell (it's held together by screws, not clips) and identify:
- Flywheel motor circuit: Two motors that spin up the flywheels (these accelerate the dart)
- Pusher motor circuit: Feeds darts into the flywheels
- Trigger switches: You'll bypass these with MOSFETs controlled by the Pi
Wire the Electronic Trigger
Replace the mechanical trigger switches with MOSFET gates controlled by GPIO pins:
# Wiring schematic (simplified):
# Pi GPIO 17 → MOSFET Gate (flywheel motor)
# Pi GPIO 27 → MOSFET Gate (pusher motor)
// ... full implementation in project files
Fire sequence: spin up flywheels (GPIO 17 HIGH, wait 500ms for full speed), then engage pusher (GPIO 27 HIGH for ~200ms per dart).
Build the Pan/Tilt Mount
Mount the bottom servo (pan/yaw) to a stable base — a piece of plywood, a lazy susan, or a 3D-printed platform. Stack the second servo (tilt/pitch) perpendicular on top. Mount the blaster to the tilt servo horn with zip ties, bolts, or a 3D-printed bracket.
Mount the Camera
Attach the webcam or Pi Camera directly to the blaster, aligned with the barrel. It needs to move with the turret so the camera's center always matches the firing line. A small zip tie or camera mount bracket works perfectly.
Face Detection with OpenCV
Install OpenCV on the Pi and use a Haar cascade or a DNN-based detector:
import cv2
import RPi.GPIO as GPIO
from time import sleep
// ... full implementation in project files
MobileNet SSD or use mediapipe for real-time face mesh tracking. Color-based tracking (chase the red shirt) is even simpler — use HSV thresholding.Tune & Test
Key variables to dial in:
- Servo speed/smoothness: Use proportional control (error × gain) instead of fixed steps to avoid jerky movement
- Flywheel spin-up time: Too short and darts dribble out. 400–600ms is typical.
- Dart feed rate: Pusher motor pulse duration controls single-shot vs. burst vs. full-auto
- Dead zone size: Too small = constant jitter. Too large = inaccurate. Start at 30px, adjust from there.
Add the Kill Switch
Wire a big red button between the battery and the entire motor circuit. When pressed, everything stops — no software involved. This is a hard requirement for any competition entry at Clanker Corral. No kill switch, no arena.
Competition Ready?
The Nerf Sentry is a showstopper at any robotics event:
- Target Challenge: Set up targets at various distances and angles. Score based on accuracy, acquisition time, and engagement speed.
- AI Demo: The face-tracking capability alone demonstrates real computer vision. Judges eat this up.
- Freestyle: Put it behind a cardboard fort, add sound effects, give it a name. The crowd goes wild for an autonomous turret with personality.
- Team Defense: In team-based events, a stationary sentry guarding your base while your mobile bots go on offense is a legitimate strategy.
Upgrades & Variants
- Mobile turret: Mount the whole rig on a Roomba (see our Roomba guide) for a roaming sentry
- Voice activation: Add a microphone + wake word detection ("fire!") using Porcupine or Vosk
- Friend-or-foe: Train a simple classifier to recognize team colors or specific faces — only fire at opponents
- Multi-barrel: Mount two blasters for dual-wielding madness